


作者: daka
時間: 2005-10-28 00:05
樓主提議不錯,我也琢磨過。但不知道怎麼弄。我手頭有兩套機身。
作者: Andy_Tsay
時間: 2005-10-28 09:38
我也很想試
作者: 英展豪
時間: 2005-10-28 09:53
這主義我之前也想過,應該不難!看來大家都很有想法ㄟ!哈
作者: gwagwa
時間: 2005-10-28 10:06
請看此連結
CH-47很好的主意 可是此時的陀螺不在控制尾舵 而是再平衡兩主旋一的轉速來鎖頭
如果大家能想出一個簡單的方法 結合陀螺來組一個類似HIROBO的中央控制MIX
非常有看頭

努力想

努力想
作者: tudole
時間: 2005-10-28 10:22
瞞困難的
兩隻主軸的動力系統必須聯在一起(可以用皮帶) 否則很難控制扭力上的差別
兩隻主軸的距離不要太長 越長越不穩定 兩旋翼面可以重疊
這個構型叫 tandem rotor 就跟CH7 chinook 一樣是直昇機控制工程的最大惡夢

光方向舵的控制就有許多不同的方法 differential collective, differential cyclic, front rotor cyclic and aft rotor cyclic. 操作的方法也有很多
再設定遙控器時要先決定你要選擇哪總控制邏輯 最好是有Futaba10ch所以比較容易編寫混控邏輯 在Y和Z軸最好都裝一個陀螺儀 Y軸因為兩個旋議會有推力差所以也會不穩定
這project很有挑戰性 但是不是不可能 有興趣的人我們可以交換意見
作者: gwagwa
時間: 2005-10-28 10:38
我在想
將雙主軸的PITCH保持一定
尾馬達的轉速由陀螺來決定 如控制同普通直昇機尾旋翼的PITCH 來鎖頭
可是尾主軸的PITCH也要隨著尾馬達的轉速而改變 保持機身平衡 此時需要用到 THRO-PITCH的MIX
大家用力想
作者: chinlin
時間: 2005-10-28 10:58
不知誰有雙軸雙槳直昇機呢....
把相關的動作一一列出來
做為DIY的參考依據
要先玩過 再來DIY會比較容易
但是模擬器的好像沒有裝軸雙槳直昇機耶
如果有 有人可以貢獻一下嘛
感恩
如果大家DIY出來的話
align說不定可以堆出轉換的昇級套件(比如可把多出來的450xl兩個合併成一個套件
(雙馬達傳動組....三槳轉換組.....)
那就更精采了 保證RC世界大轟動


作者: 狗醫生
時間: 2005-10-28 11:25
http://tech-mp.com/kits.htm看看這個吧
作者: chinlin
時間: 2005-10-28 11:46
看來有參考對象了 @_@~~~
http://tech-mp.com/dragonfly_pro.htm更清楚
作者: Andy_Tsay
時間: 2005-10-28 11:48

參考一下
作者: Andy_Tsay
時間: 2005-10-28 11:56
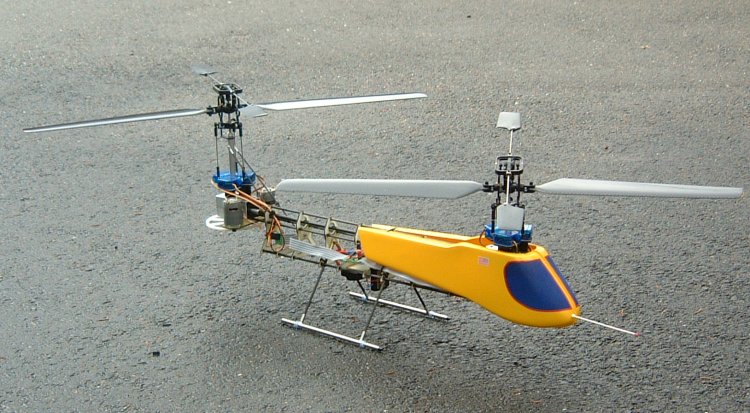
雞婆一下
作者: gwagwa
時間: 2005-10-28 12:10
HIROBO CH-47 適用皮帶將前後兩主軸相連的 因此轉速前後相同
如果控制尾主軸的ALI 可控制轉向 PITCH 可控制 前後
如果前後控制同步 就可控制 上向 與滑左滑又
好像是個比較簡單的方法
作者: tudole
時間: 2005-10-29 04:34
Two main rotors HAS to be mechanically connected. Problem #1: NO governor can do such a good job to make two rotors rotate at same speed; if governor on each rotor interfere to each other, it might get worse. Problem #2, as my earler post, the distance of two shafts has to be as short as possible, to make the yaw channel more stable. As the result, there are some overlapping disk area. If both rotors are not mechanically connected together, the blades will hit each other.
However, it is a good idea to use a governor in a mechanically connected tanem rotor. If the rpm is constant, the rotor torque will only come from the collective pitch setting of each rotor. That will save a lot of trouble.
I want to the link of Hirobo CH47, and breifly looked at it. It needs a "tandem rotor control mixer" and a 3 axis gyro. unfrotunately, the website doesn't say how the control logic works. My best guess is that, the gyro issues the rate damping command in all 3 axis to the mixer and the mixer will tell the lateral/longitudianl control servos in both forward and aft rotors. Can anyone confirm this?
Let see what problem we are going to face:
1. Yaw control
Yaw control has to go through a. differential lateral cyclic (one rotor to turn right and the other to turn left). b. Differential collective pitch (one rotor has higher thrust than another, so the torq on the first one rotor is higher)
2. Pitch control.
In hover, the pitch control is done by a. longitudinal cyclic in both rotors. b. differential trust (collective) in both rotors.
Also, if the CG is not dead on the center of 2 rotors, the unbalance has to be adjusted by the differetial thrust. Note that 1.a and 1.b. are coupled.
3. Roll control
Lateral control is easier compare to the other 2 channels. It can be done on lateral cyclic on both rotors.
4. Rotor coupling
Rotor blade flapping is coupled in a 90 degree phase. When you do a pitch command, the roll will be slightly affected, depends on the stiffness of the rotor in theory. Luckily, I didn't feel so much when I fly a T-Rex.
5. Wind/forward flight
When wind blows from the nose (or flying forward) the advancing blade on both rotors are in different side. That will make the helicopter to yaw.
Above are a simplified senario of the problem. I will look at more document to see how the control logic should work.
I hope someone can traslate this....
| 歡迎光臨 亞拓遙控世界討論區 (https://forum.align.com.tw/) |
Powered by Discuz! X2.5 |